|
Yuzhou Cheng(程誉洲) Hi, I am a second-year PhD student in the Dyson Robotics Lab at Imperial College London, under the supervision of Andrew Davison and Pedro Mediano. Previously, I received my BSc from CUHK-Shenzhen, supervised by Zhi-Quan Luo, and my MSc from UCL, supervised by Dimitrios Kanoulas. How can robot vision lead to spatial intelligence? I explore this question through distributed inference frameworks and 3D representations. |

|
Research |
|
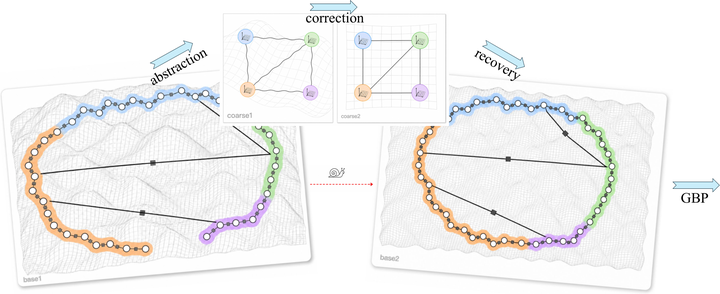
Hierarchy-GBP: Accelerating Factor Graph Inference via Abstraction and Recovery
Yuzhou Cheng, Tom Yates, Ignacio Alzugaray, Danyal Akarca, Pedro A. M. Mediano, Andrew J. Davison arXiv, 2026 arXiv / code A hierarchical Gaussian belief propagation framework that accelerates Pose Graph Optimization and Bundle Adjustment. |

|
MLP Splatting: Object-Centric Neural Fields
Shinjeong Kim*, Yuzhou Cheng*, Xin Kong*, Paul H. J. Kelly, Andrew J. Davison ECCV, 2026 (* equal contribution) project page / arXiv / code Object-centric neural primitives for photorealistic rendering and interactive scene editing. |

|
Belief Propagation Converges to Gaussian Distributions in Sparsely-Connected Factor Graphs
Tom Yates, Yuzhou Cheng, Ignacio Alzugaray, Danyal Akarca, Pedro A. M. Mediano, Andrew J. Davison ICML, 2026 project page / arXiv A theoretical account of when beliefs become Gaussian in sparse, loopy factor graphs. |

|
LoGS: Visual Localization via Gaussian Splatting with Fewer Training Images
Yuzhou Cheng, Jianhao Jiao, Yue Wang, Dimitrios Kanoulas ICRA, 2025 project page / arXiv / code Few-shot visual localization using a compact 3D Gaussian Splatting map. |